Summary Coursework Experience Education Leadership Skills Projects Contact

GN&C / Autonomy Engineer

Flight software and simulation should be reliable. I aim to build models, estimation systems, and simulation-backed verification evidence.

Propulsion Engineer II at Lockheed Martin Space.
M.S. student at the University of Colorado, Boulder, focused on estimation, tracking, and decision making under uncertainty.
Targeting GN&C and autonomy roles in Seattle, WA.

(303) 817-5144
United States Citizen

Summary

Jack Huston

I work on flight hardware programs where requirements, test evidence, and risk reduction matter. At Lockheed Martin Space, I support deep-space propulsion systems through verification work, anomaly investigations, and data-driven performance assessments.

  • Review thruster qualification and acceptance test data, then turn results into clear requirement closure and risk calls.
  • Build and maintain MATLAB tools that standardize test data processing, keep runs traceable, and cut review turnaround time.
  • Support propulsion component selection and verification for deep-space missions, working across test, systems, and design teams.

My graduate school focus is GN&C and autonomy. My coursework builds estimation and decision-making methods that stay reliable in uncertain conditions when sensors are noisy, detections are imperfect, and the environment is only partially observed.
Current Graduate Coursework (Spring 2026)

ASEN 6084, Optical Detection + Tracking

Camera and sensor data to reliable object tracks
  • Detect faint targets in noisy imagery, quantify measurement uncertainty.
  • Track targets with missed detections, false alarms, and multiple objects.
  • Implement Kalman filtering and data association for practical tracking.
  • Study multi-target tracking methods, including multi-hypothesis tracking and set-based RFS approaches.
Kalman Filtering Data Association Multi-Target Tracking Sensor Models

ASEN/CSCI 5264, Decision Making under Uncertainty

Planning and control with hidden state and partial observability
  • Model decisions under uncertainty using probabilistic state and observation models.
  • Plan with MDPs using value iteration and policy iteration.
  • Apply reinforcement learning methods to learn policies from experience.
  • Plan with POMDPs using belief updates, including Bayesian and particle filtering concepts.
  • Cover multi-agent decision making through game theory and Markov games.
MDPs POMDPs Reinforcement Learning Belief State
What you get from this:
I complete and self-fund my graduate coursework asynchronously while working full-time. I choose classes that map to real GN&C work. I bring recent methods from school into my day-to-day work, while staying focused on the team's priorities during the workday.

Professional Experience

Lockheed Martin Space

Propulsion engineering, verification, test data analysis
Littleton, CO
May 2022 to Present
Propulsion Engineer II Feb 2025 to Present
  • Own analysis and verification workstreams for deep-space systems, focused on requirement closure and risk reduction.
  • Build and maintain MATLAB tooling to improve repeatability, traceability, and turnaround time for qualification and acceptance reviews.
Propulsion Engineer I Jul 2023 to Feb 2025
  • Supported component selection and verification, ensured hardware met mission requirements and integrated cleanly with the vehicle.
  • Contributed to a lunar lander transportation program supporting Blue Origin HLS through the CIS Lunar Transporter vehicle team.
  • Built MATLAB tools to automate thruster test data review for qualification and acceptance campaigns, improved consistency and reduced manual processing.
  • Built fast what-if vehicle models to answer design questions under rapid iteration, then translated outputs into clear verification evidence.
Propulsion Engineer Intern May 2022 to Jul 2023
  • Developed test procedures and executed performance assessments for additively manufactured filters on deep-space monopropellant applications.
  • Summarized results into engineering recommendations to guide manufacturing and design decisions.

Teaching Fellow

University of Colorado Boulder
Boulder, CO
Aug 2021 to May 2023

Led labs and office hours for Thermodynamics, Aerodynamics, Dynamics, and Electronics. Supported 100+ students per semester with hands-on demos and data-first problem solving.

Education

M.S., Aerospace Engineering Sciences, Autonomous Systems
University of Colorado Boulder, Professional M.S.
(Remote/Asynchronous), GPA 4.00
Focus: Estimation, tracking, autonomy, and control software.
Aug 2025 to Dec 2027 (Expected)
B.S., Aerospace Engineering Sciences, minor in Computer Science
University of Colorado Boulder
Summa Cum Laude, GPA 3.97
Aug 2019 to May 2023

Leadership and Service

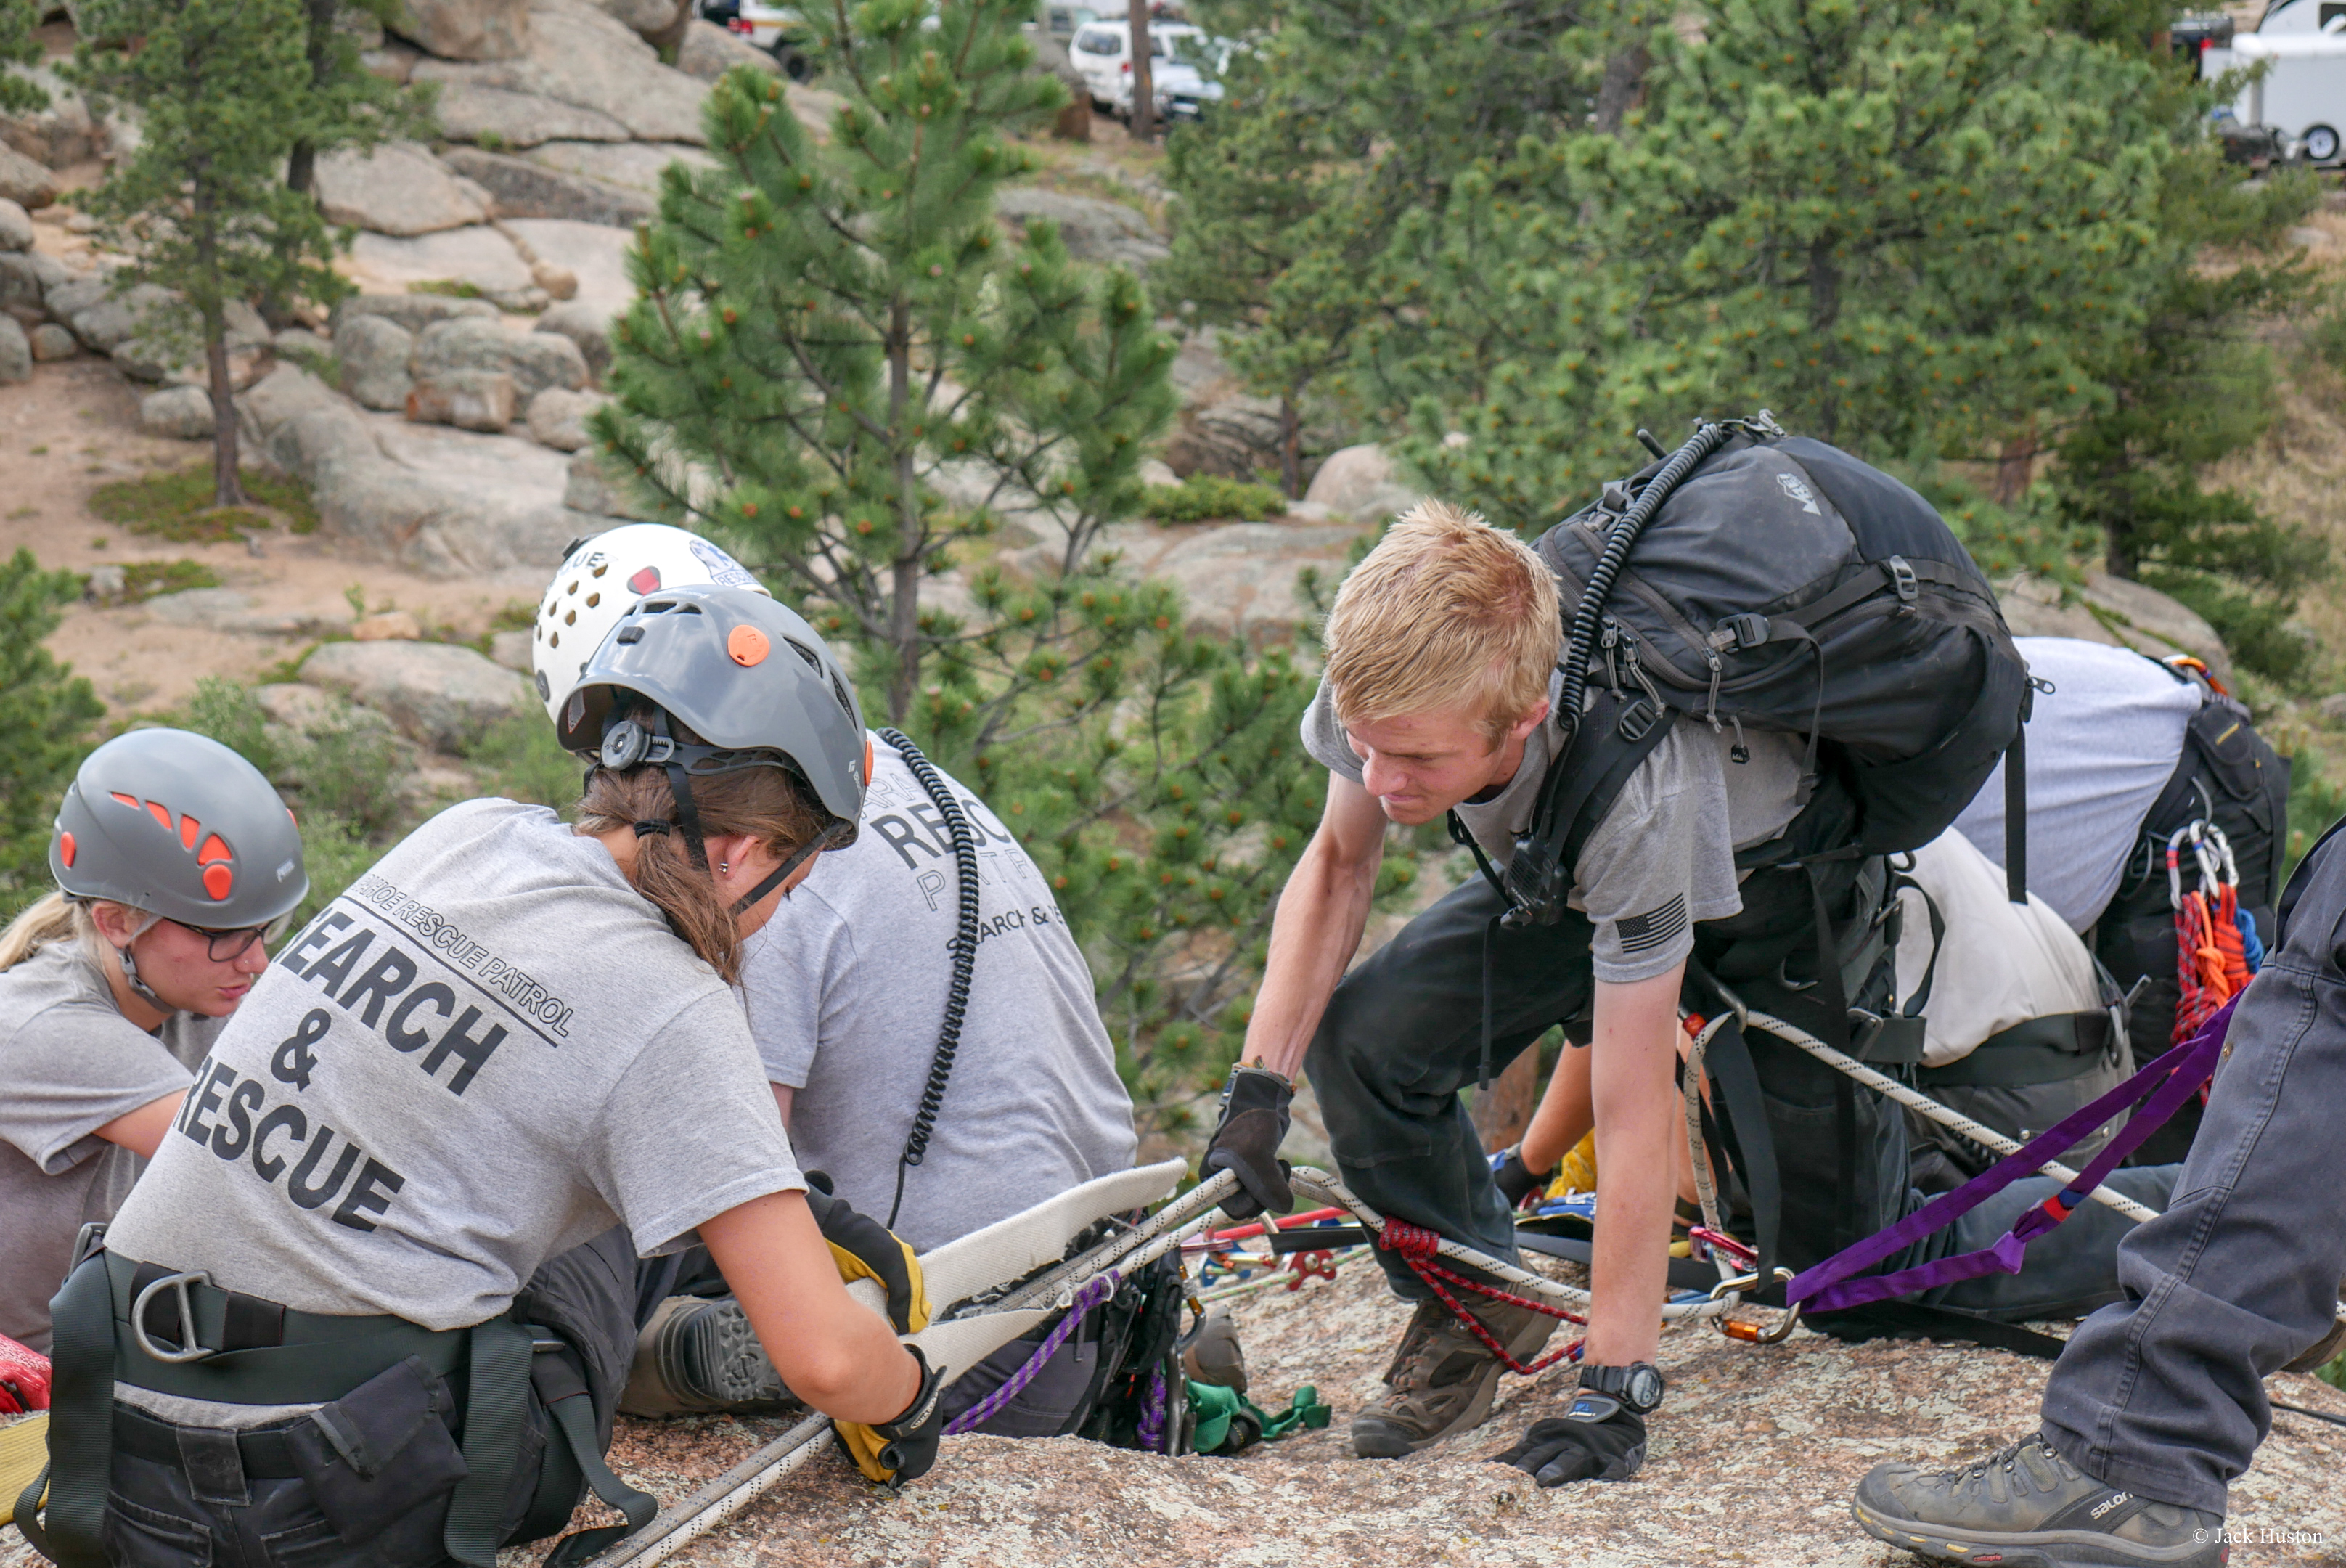
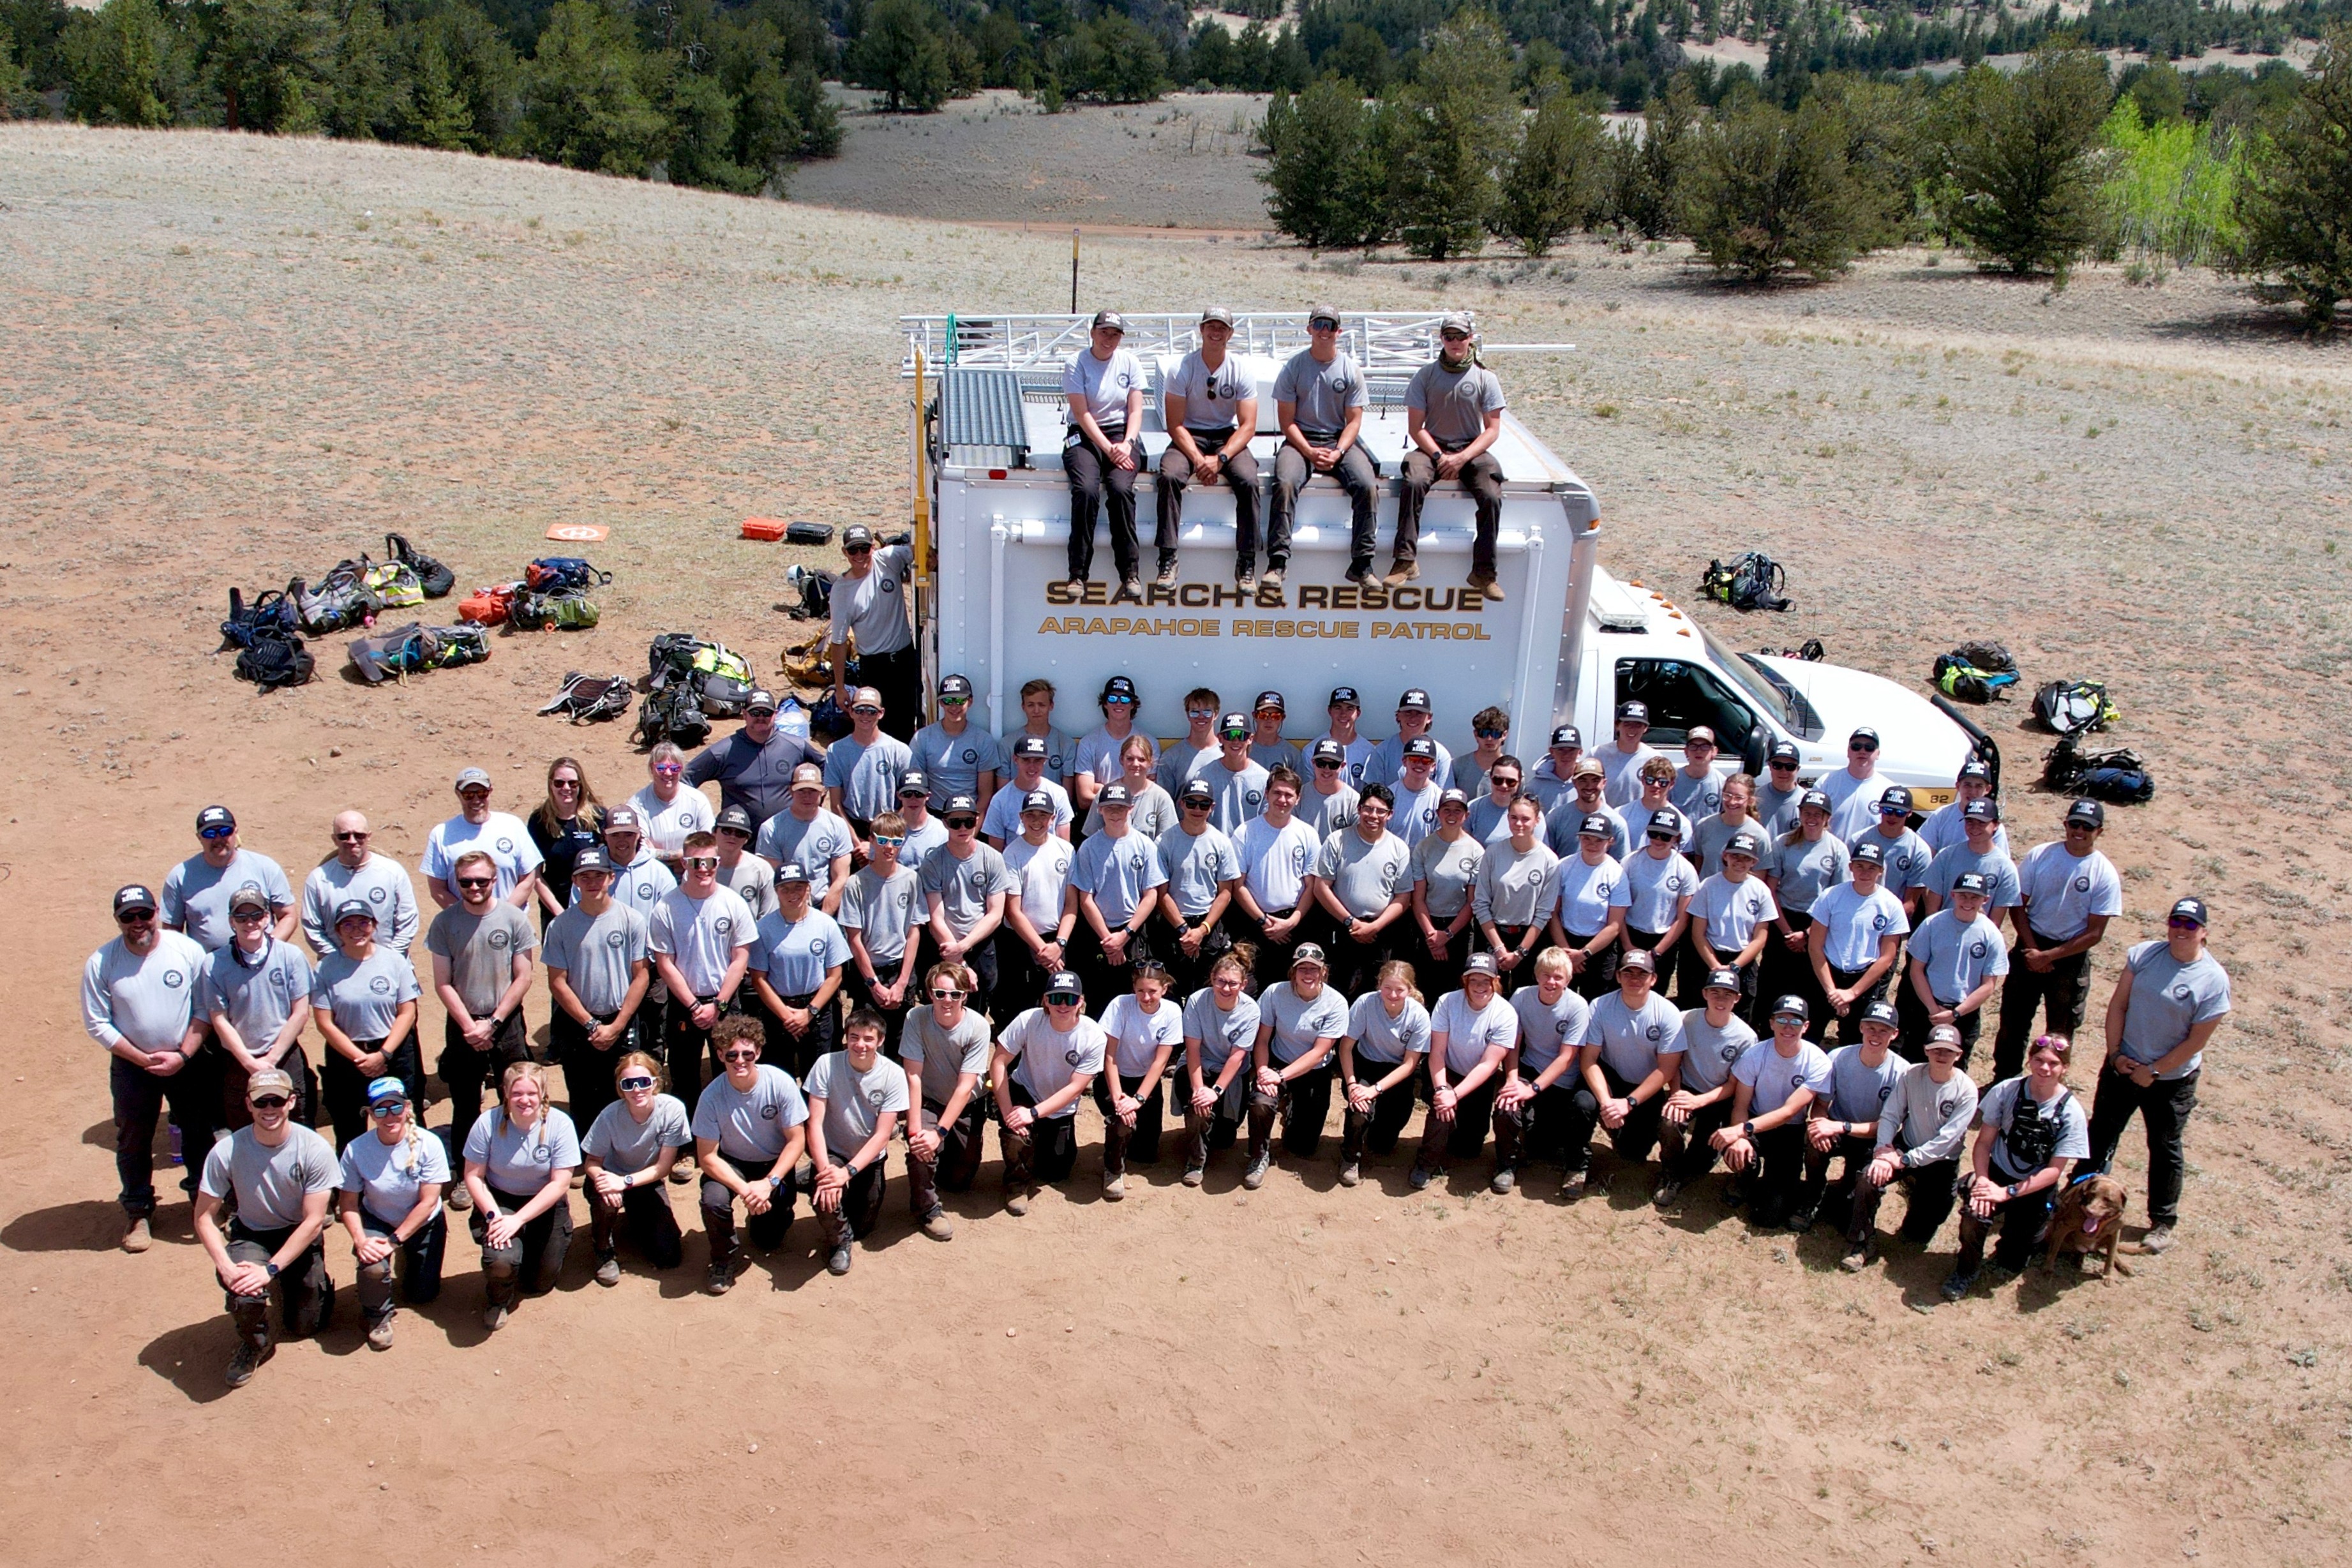
Board of Directors, Arapahoe Rescue Patrol

Director of Technology for a youth-run, all-volunteer search and rescue team. The board oversees governance, readiness, fundraising, and operational policy. I support technology rollouts and field readiness, and deploy as needed.

  • Roll out tools and processes that improve readiness and communication.
  • Set training and equipment priorities tied to safety and mission success.
  • Support after-action reviews, drive changes based on what the data shows.
Technical rescue training
Technical rescue training.
Arapahoe Rescue Patrol team photo
Team photo.

Skills and Tools

Estimation and Tracking

Kalman filtering, measurement modeling, track management, data association, and multi-target tracking concepts from ASEN 6084.

Control and Simulation

Linear control foundations, modeling and simulation, and a test-backed validation mindset. Build tools to explore what-if cases and support design decisions.

Autonomy and Decision Making

MDPs, POMDPs, belief state updates, reinforcement learning concepts, and multi-agent decision making concepts from ASEN/CSCI 5264.

Software and Data

MATLAB for high-volume data review and automation. C and C++ for embedded projects. LabVIEW for test integration. Python basics.

Featured Projects

Estimation, control, sensors, and embedded systems work you can scan fast

Orbit determination and LQR control demo
Estimation + Control Testing

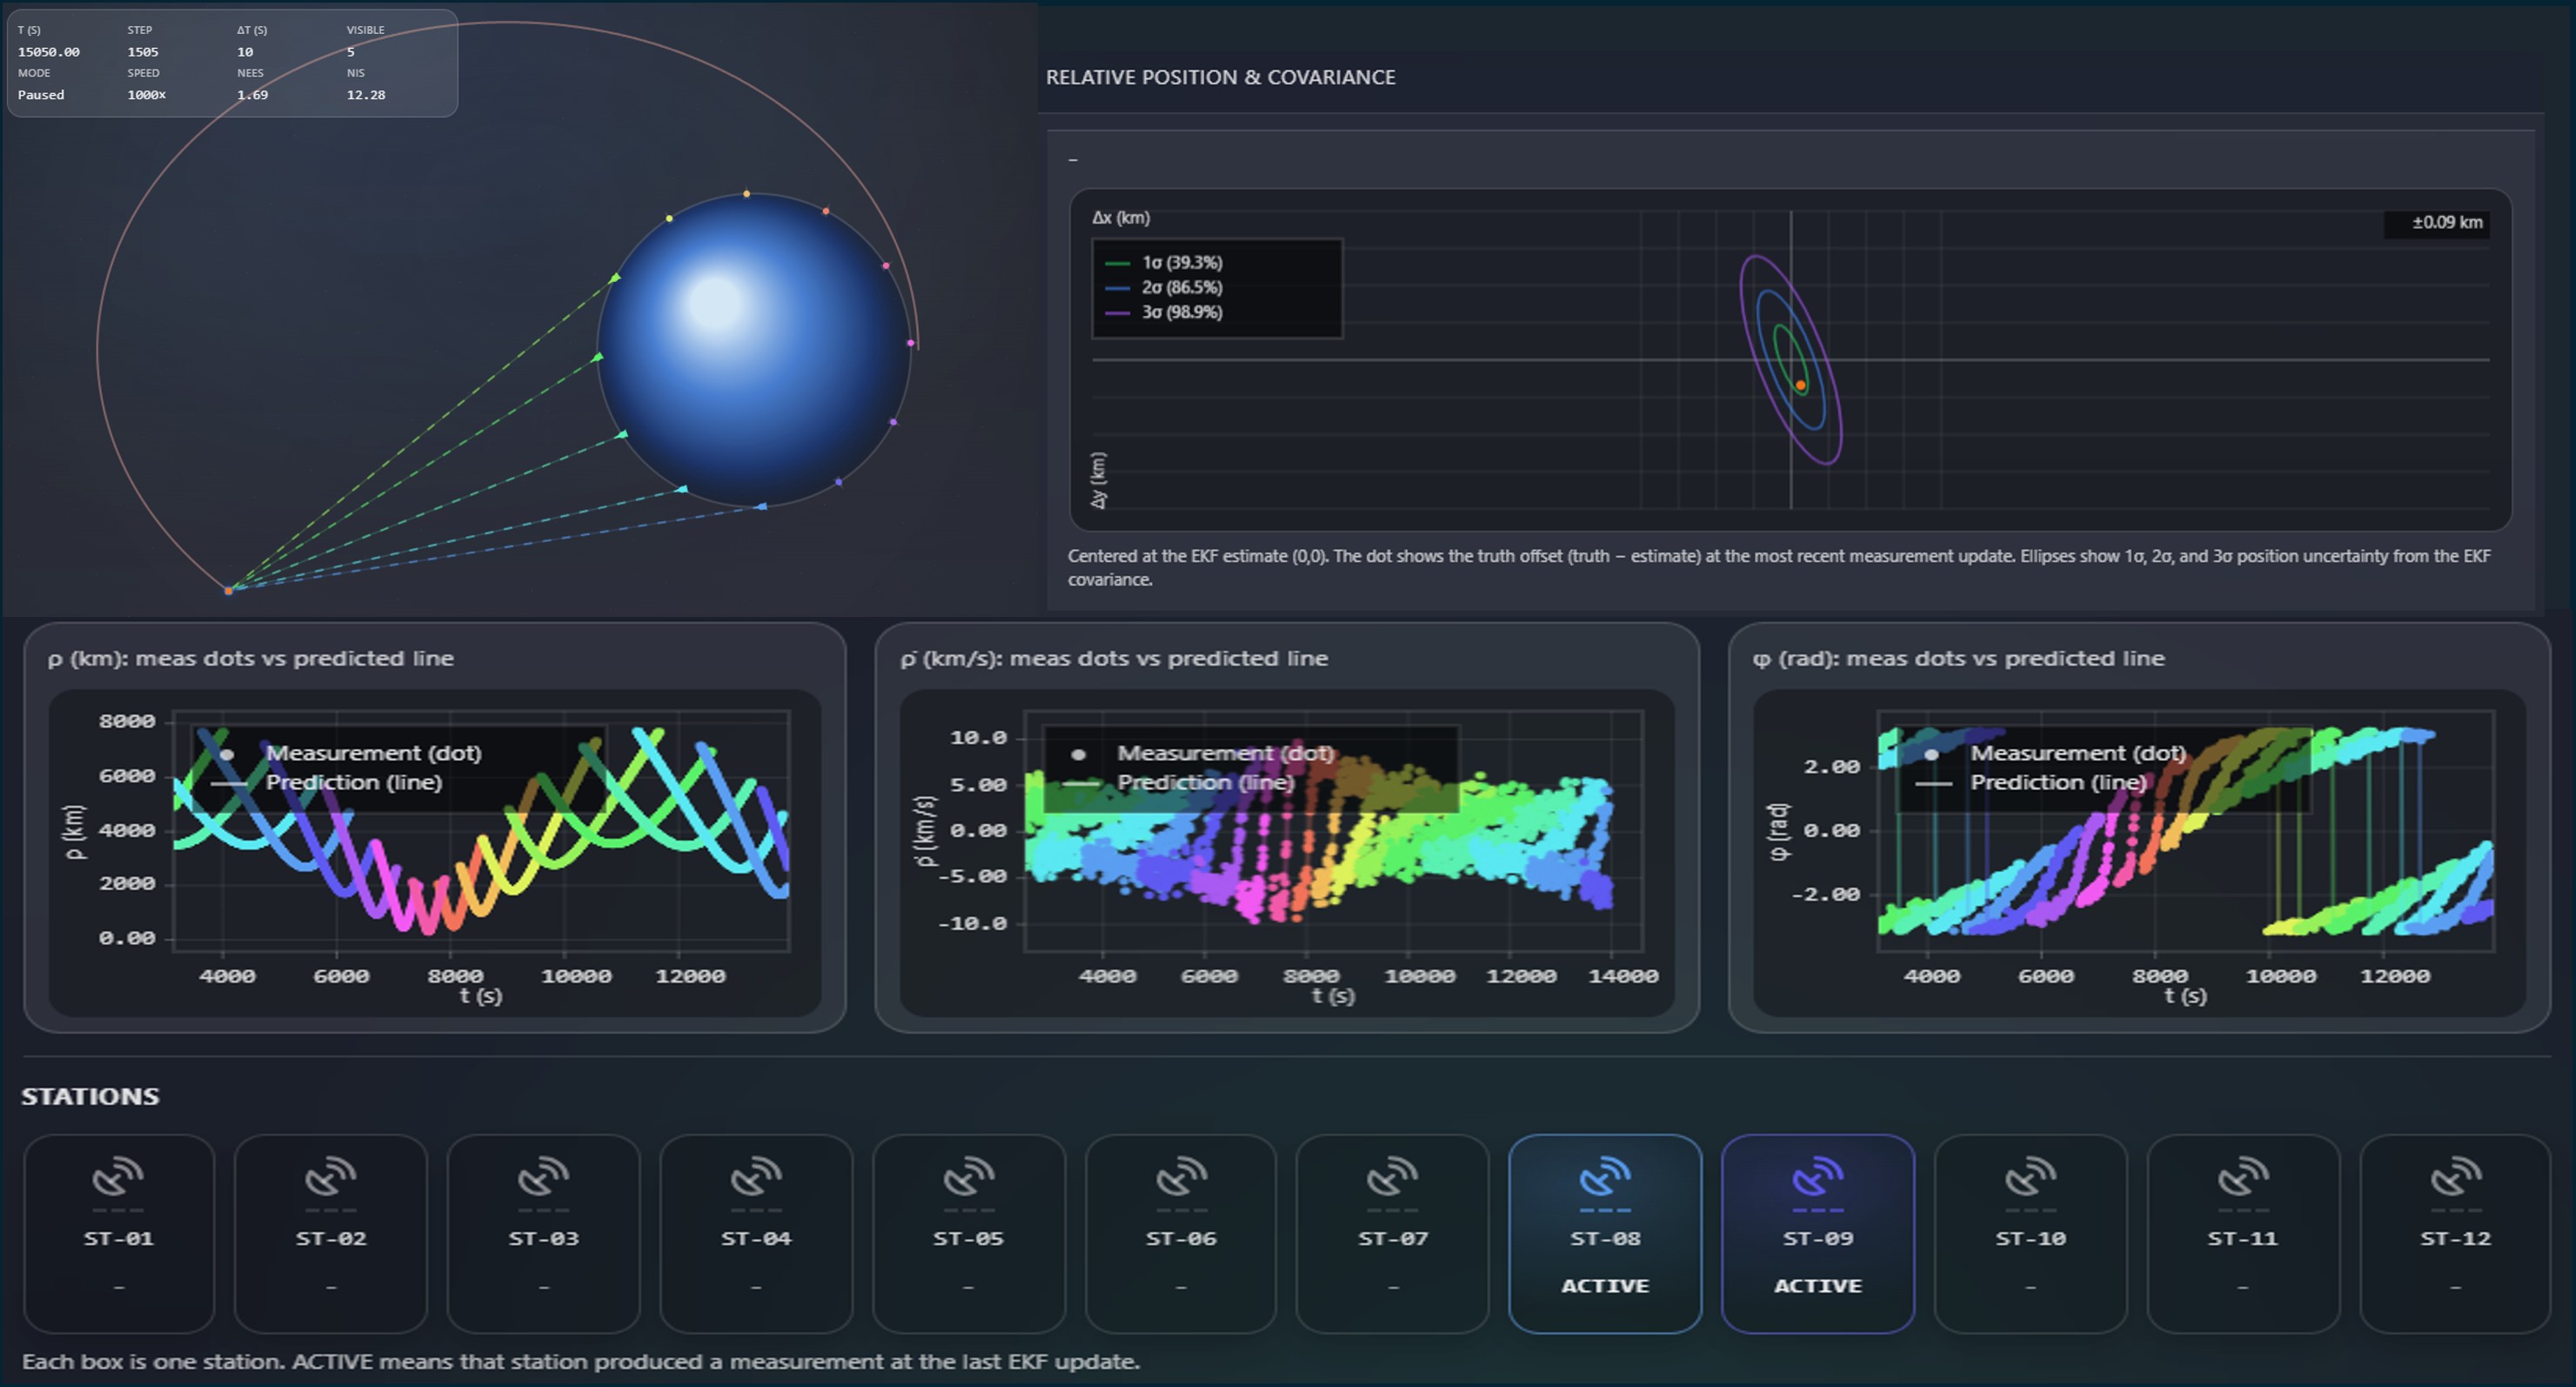
EKF Orbit Determination + LQR Orbit Control

EKF orbit determination with noisy range, range-rate, and angle measurements. LQR control uses the EKF estimate with saturation. Monte Carlo runs check NEES and NIS against chi-square bounds.

Kalman Filtering LQR Orbital Dynamics Monte Carlo NEES/NIS
Ice Plume Particle Detector
Sensor and System Prototyping

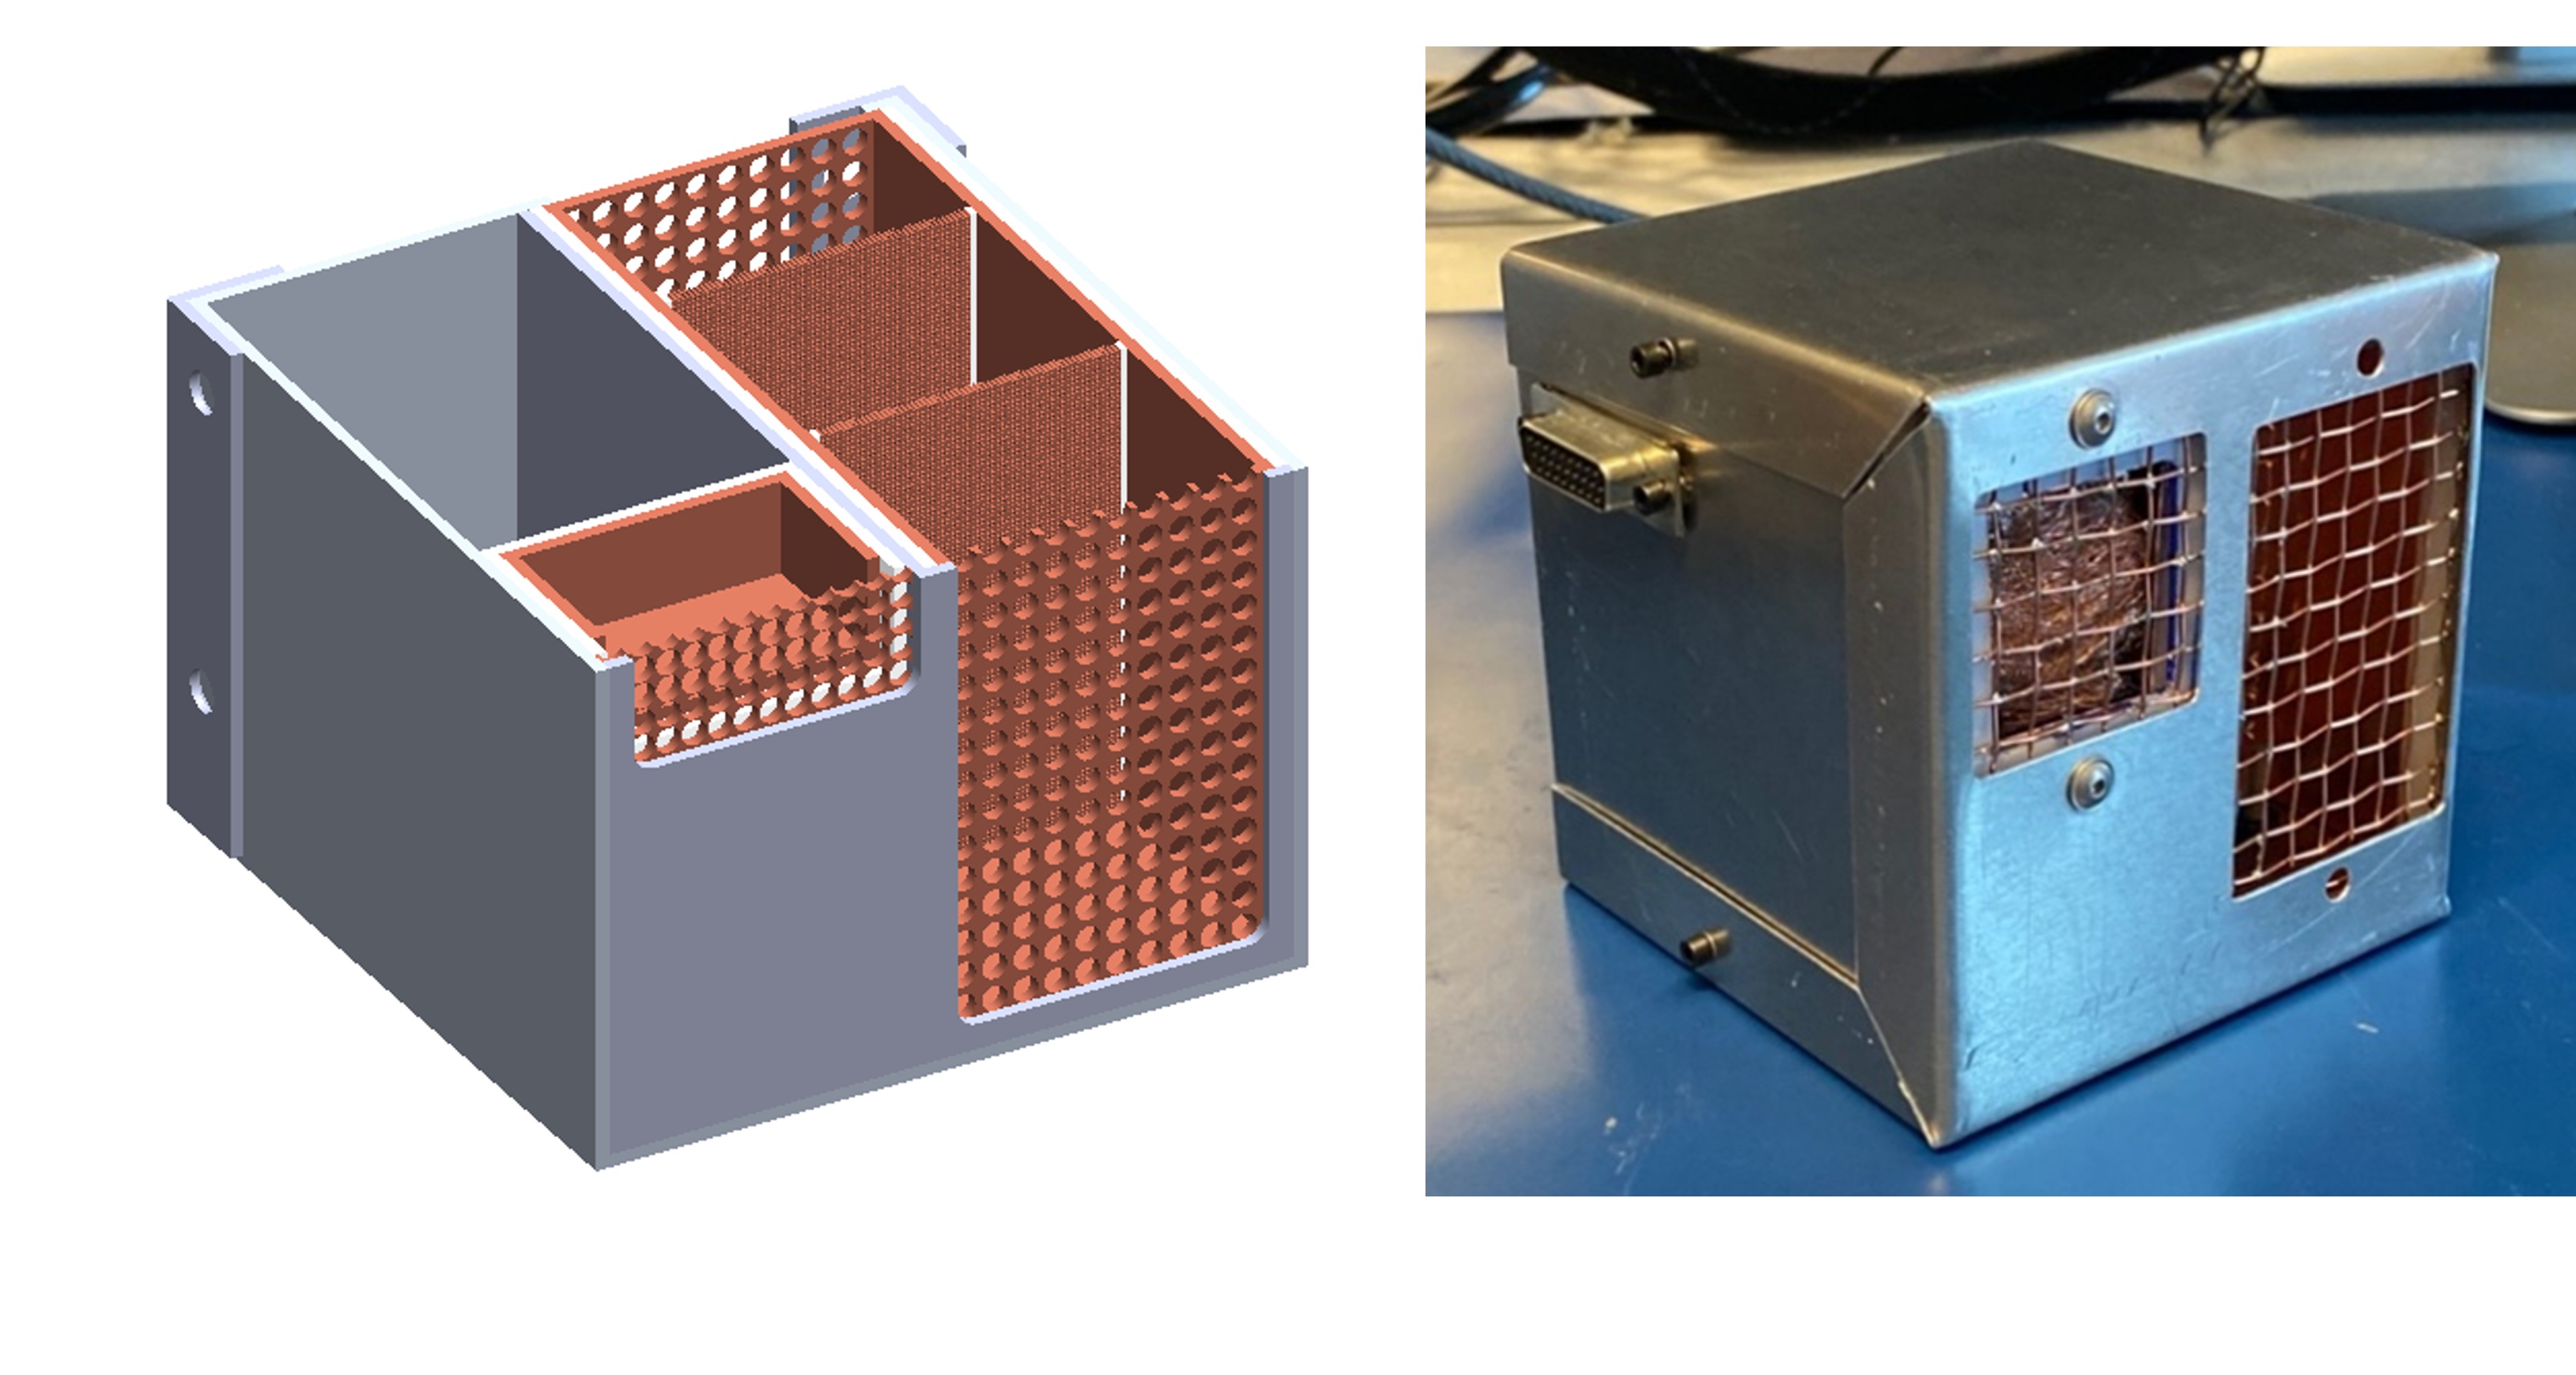
Ice Plume Particle Detector

Prototype instrument concept for detecting charged ice grains in a plume fly-through. Work covered hardware, signal paths, and test setup.

MATLAB SolidWorks C++ PCB Design Lab Testing LabVIEW
Propellant level sensor
Measurement + Calibration

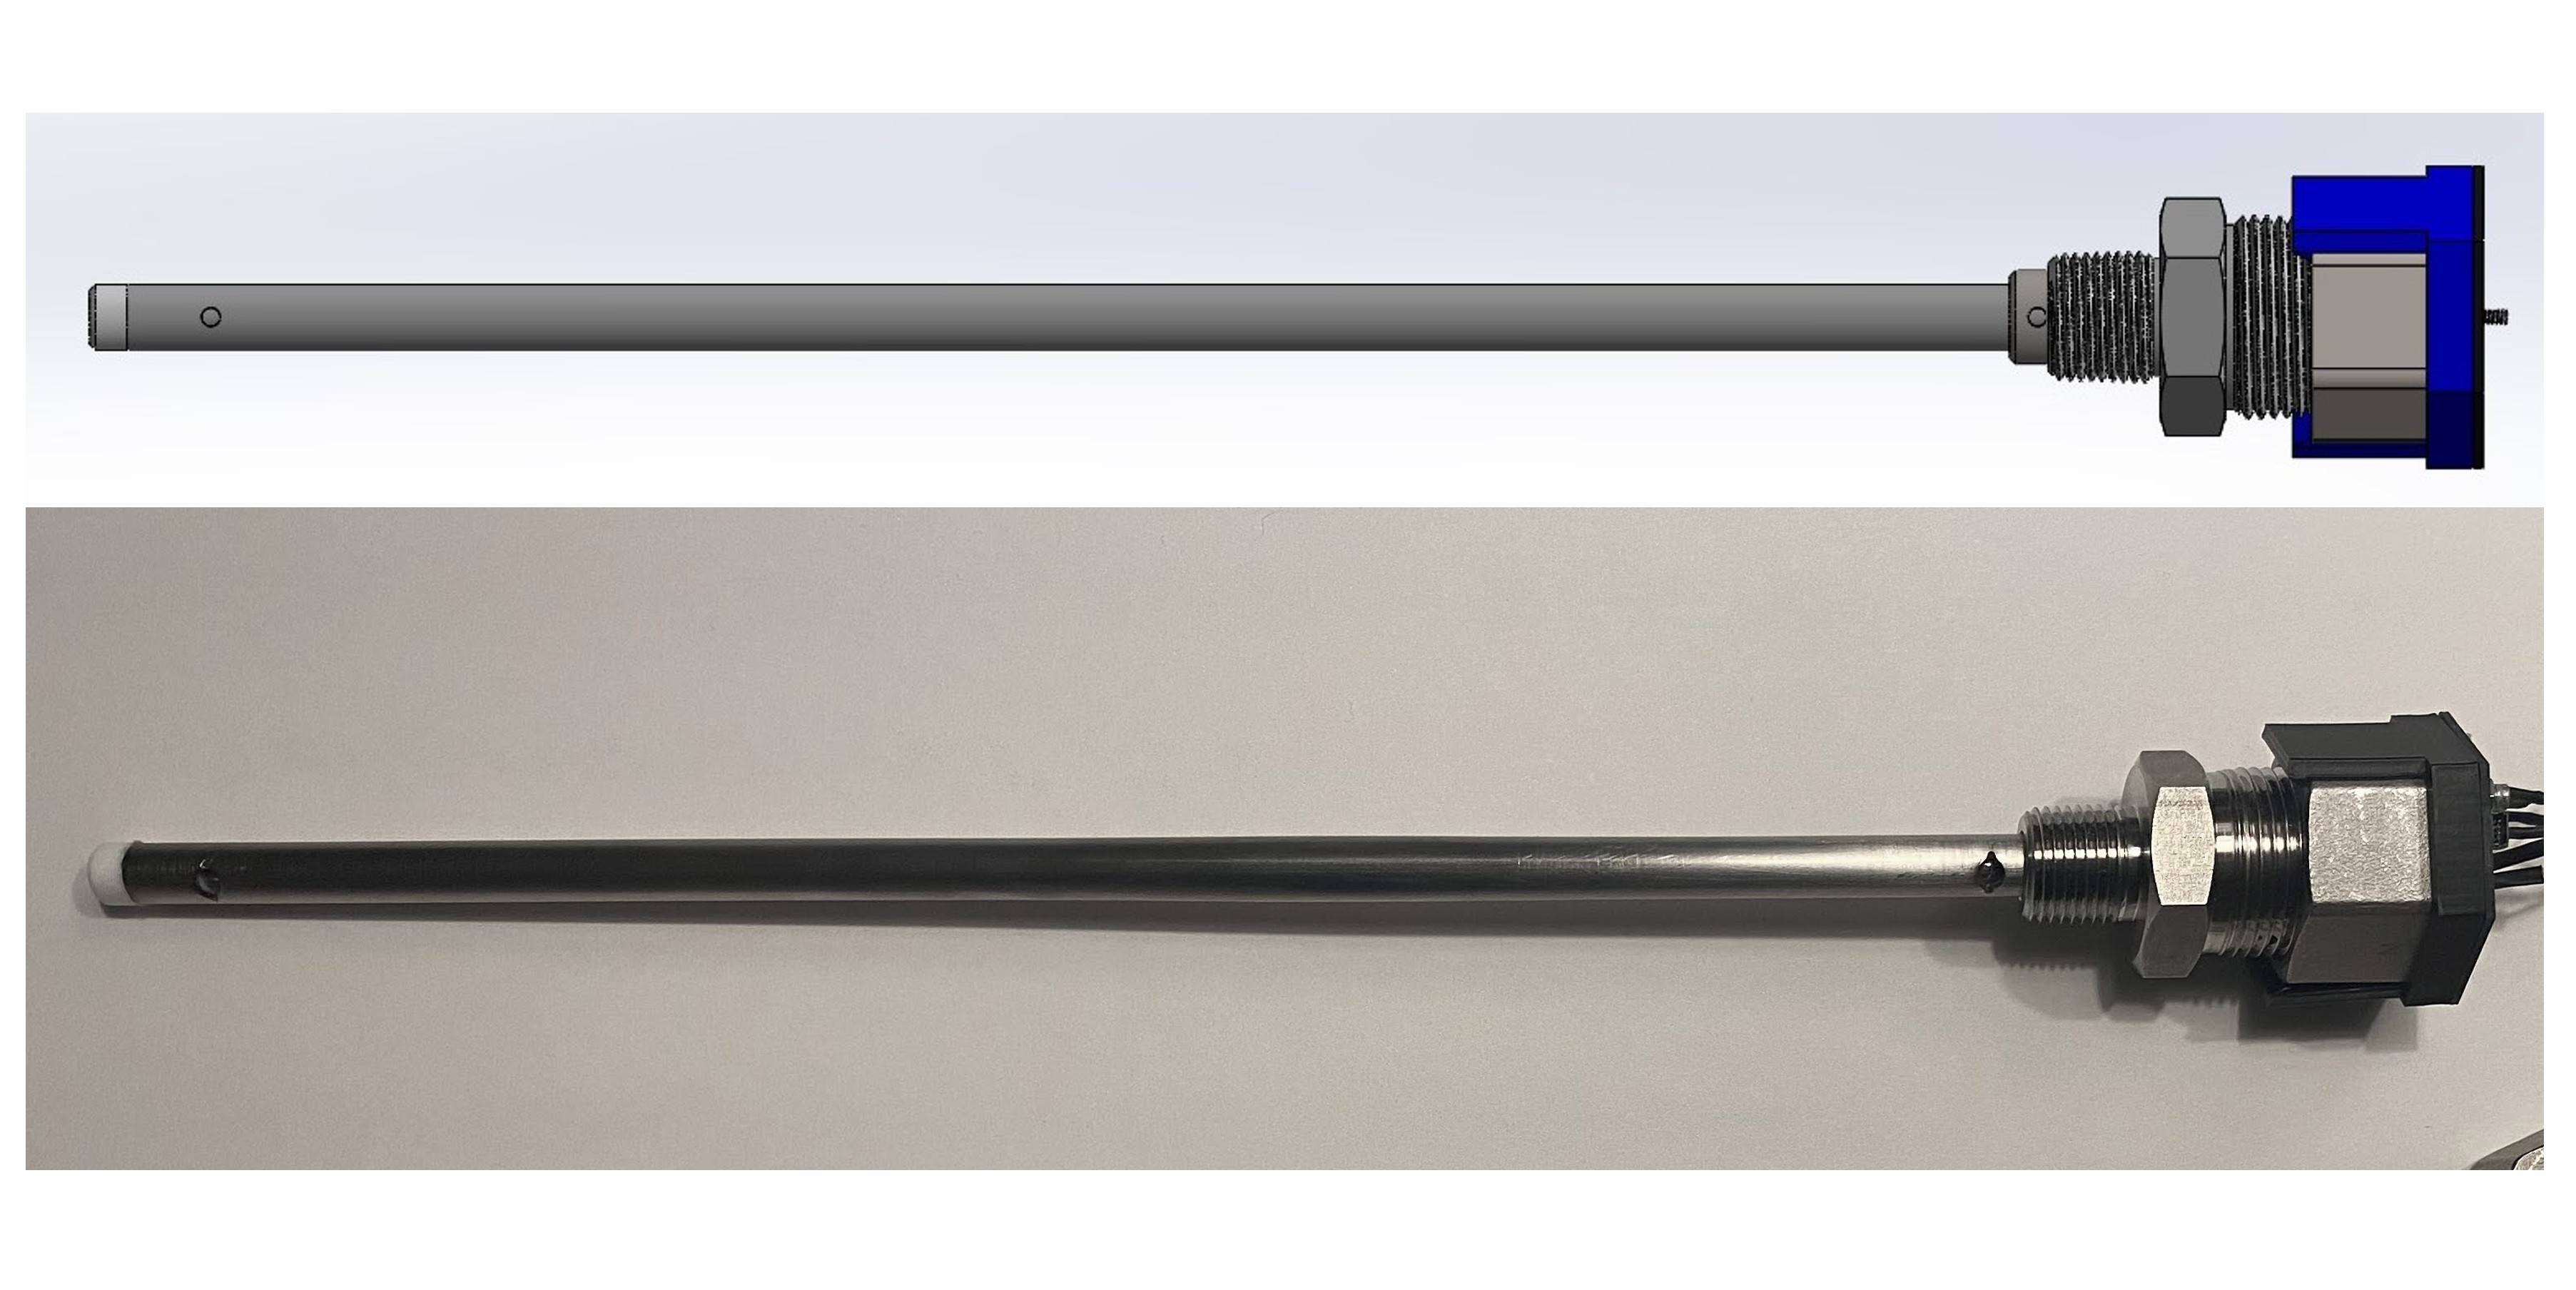
Capacitance Propellant Level Sensor

Capacitance sensor for RP-1 and cryogenic LOX tanks. Calibration and integration work supported repeatable test data collection.

C++ SolidWorks Manufacturing PCB Design Integration and Test
IoT smart lamp controllers
Embedded Systems

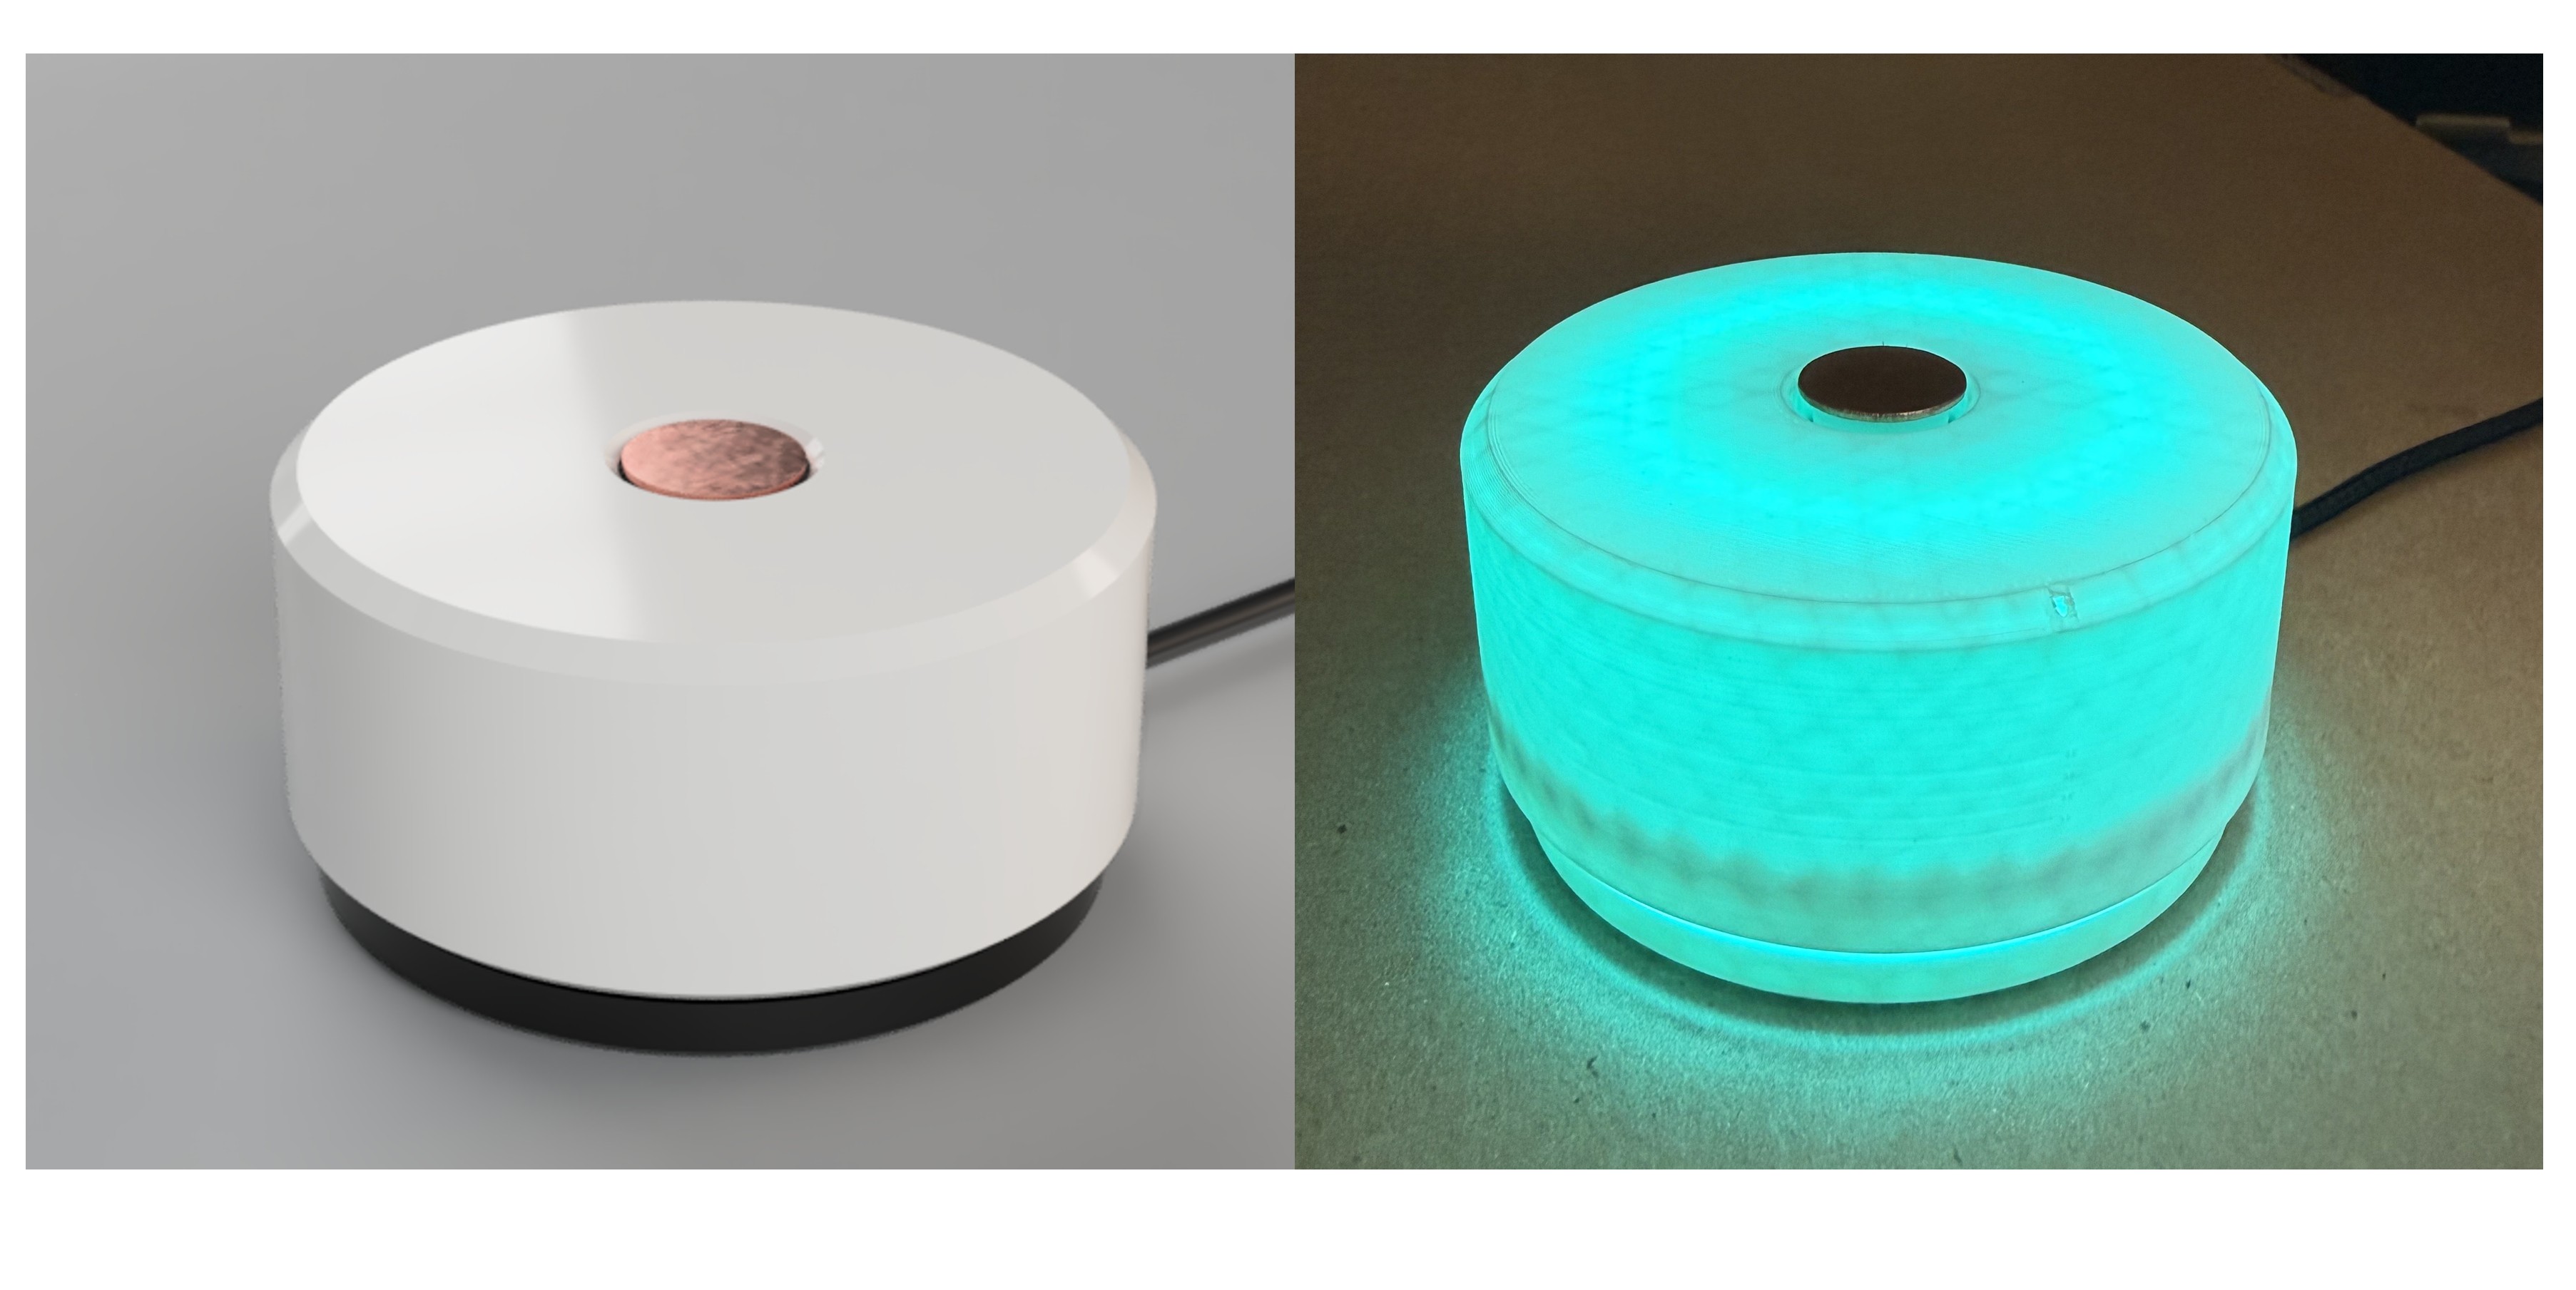
IoT Smart Home Control Lamps

Paired desk lamps that act as tactile IoT controllers. Work covered sensing, state handling, and device-to-service messaging.

C++ 3D Printing Electronics IoT Integration
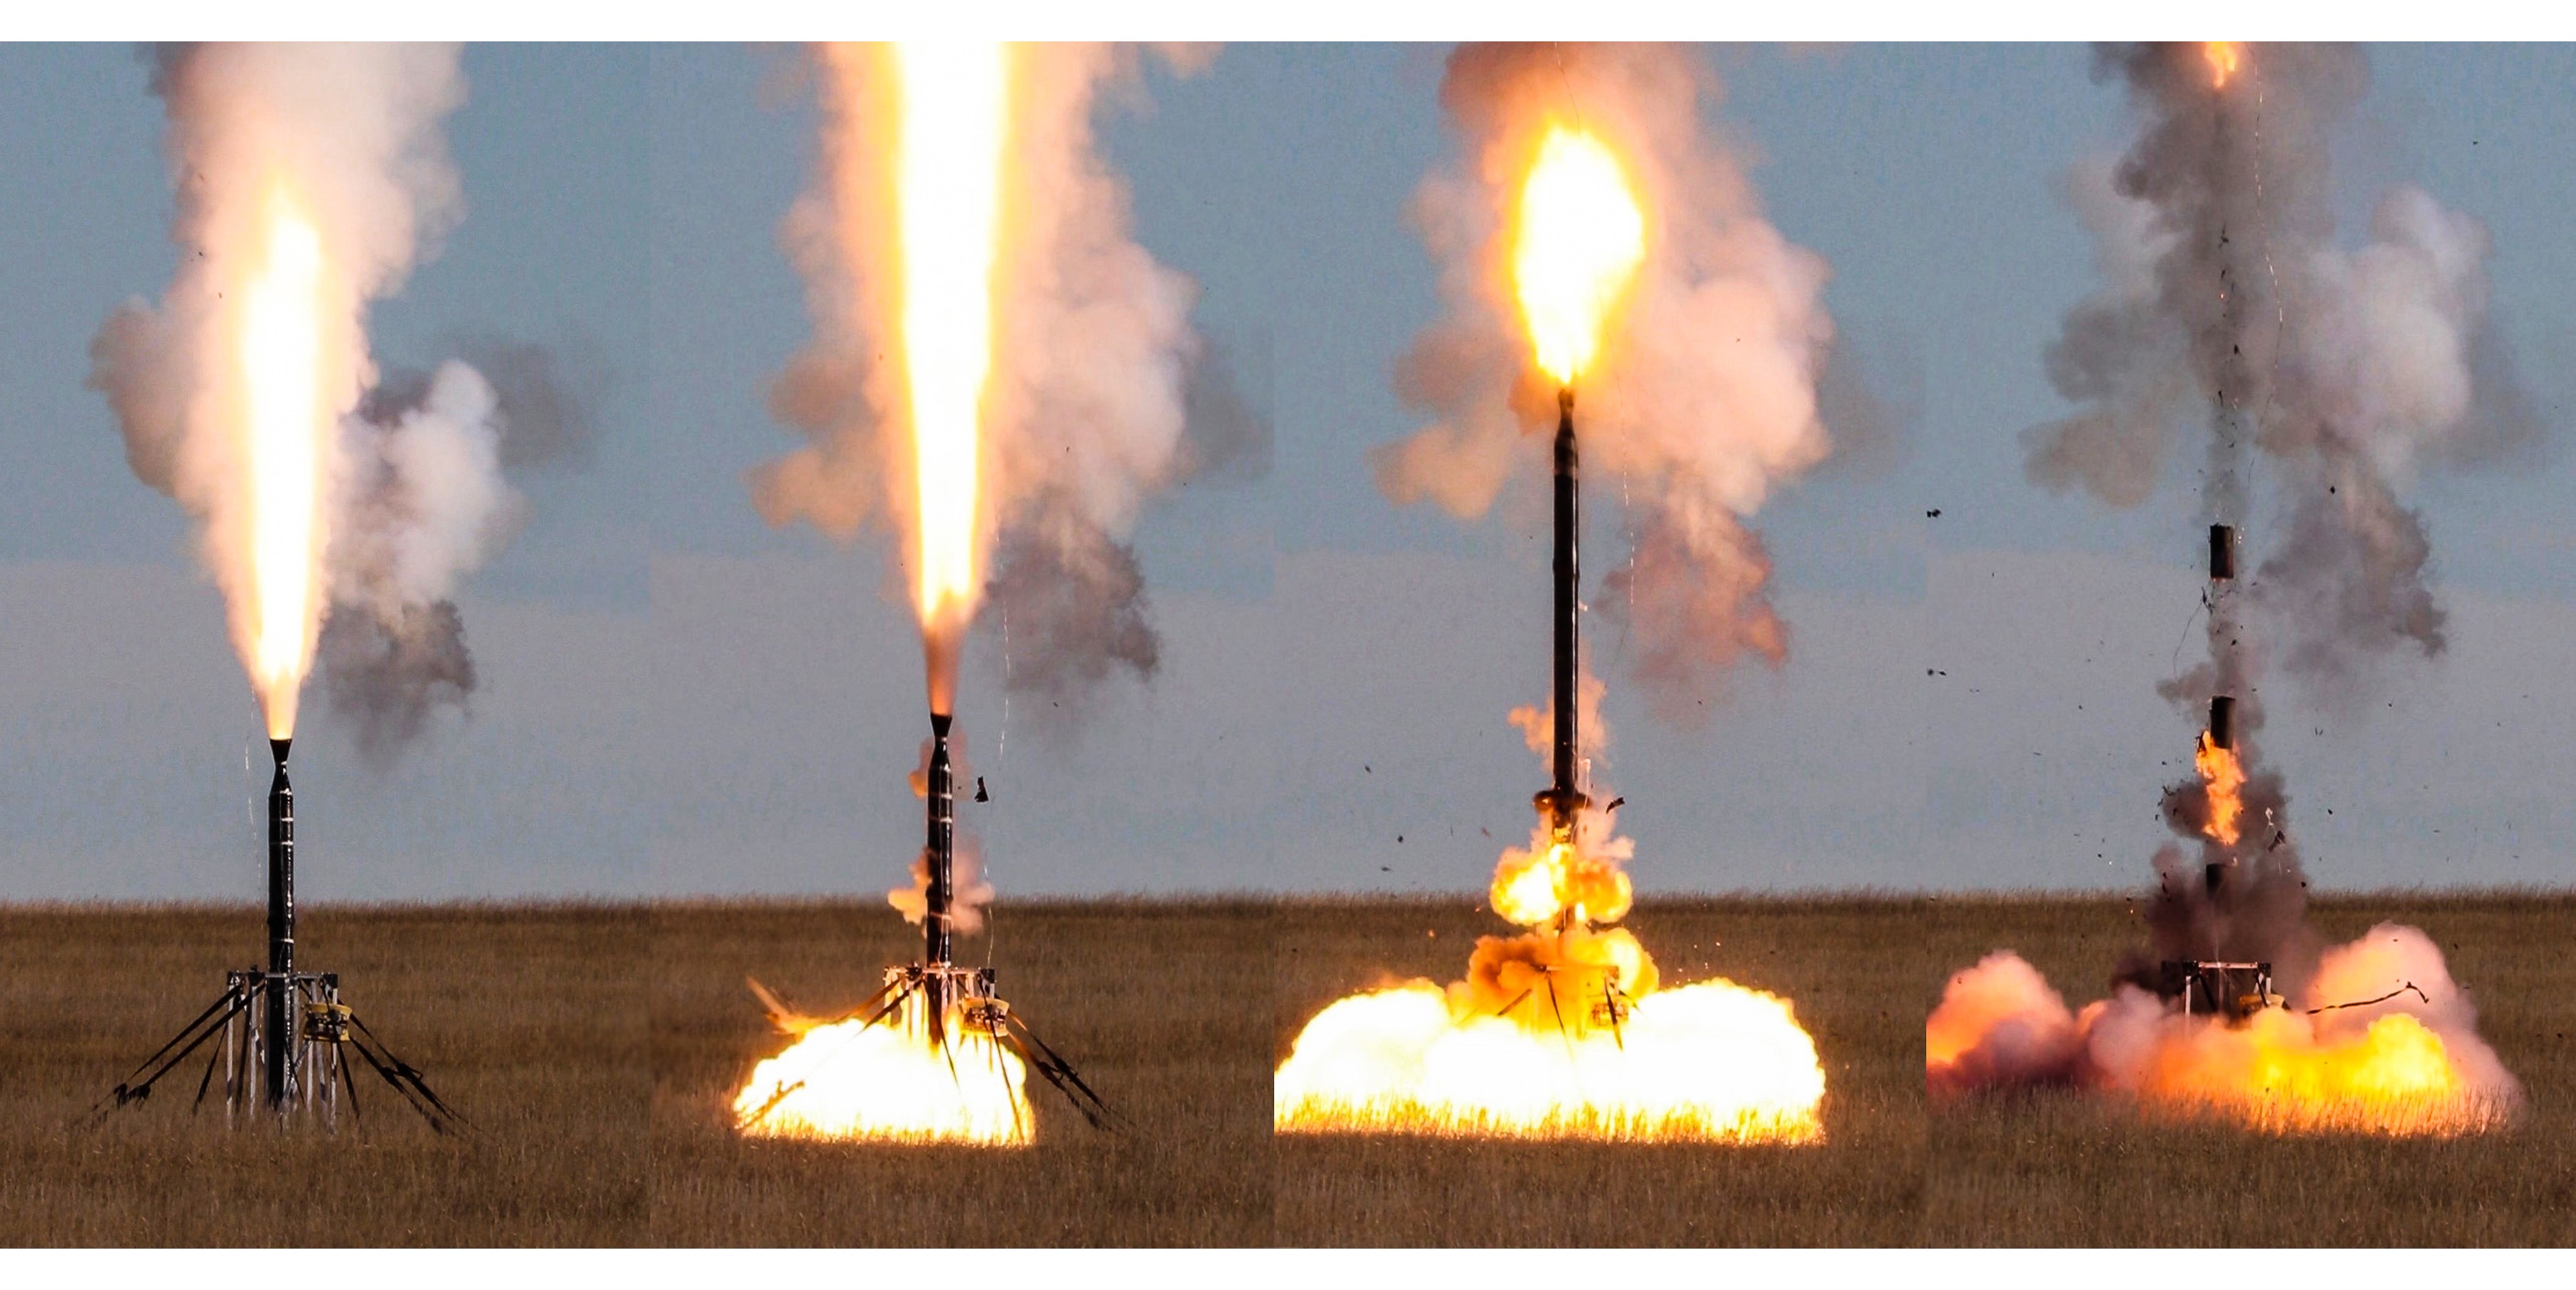
Rocket integration and test
Systems Integration and Test

Rocket Integration and Test

Sounding rocket lab work across integration, test prep, data collection, and post-test review.

Integration and Test LabVIEW Electronics Control Logic Manufacturing
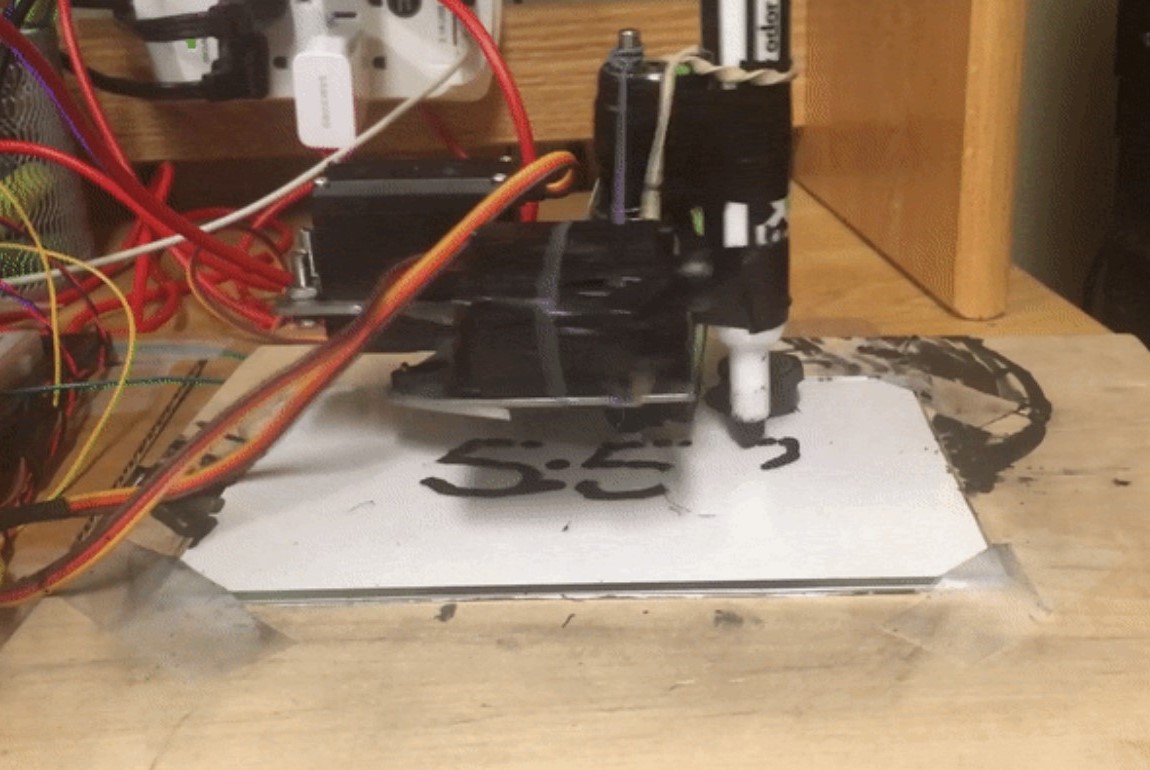
SCARA robot writing clock
Control + Mechatronics

SCARA Robot Writing Clock

SCARA robot that writes and erases the current time. Work covered kinematics, control logic, and reliable command handling.

C++ Electronics Kinematics Control Systems Manufacturing

Let’s Connect

If you are hiring for GN&C, autonomy, or modeling and simulation in Seattle, let's chat! Reach out by email or LinkedIn below.

Copied to Clipboard